Repository navigation
TurtleBot3_SLAM
This example performs SLAM using a Laser Distance Sensor.
For the specifications of Laser Distance Sensor, please refer here.
Start the Ubuntu side and then the Windows side.
Open a new terminal and run the following command:
ros2 launch sigverse_turtlebot3 slam_launch.xmlStart the [Assets/SIGVerse/ExampleScenes/Turtlebot3/SLAM(.unity)] scene with reference to this page.
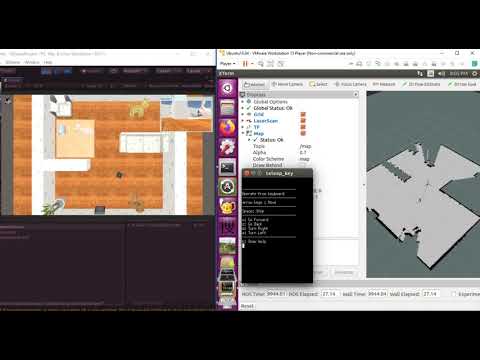
You can control TurtleBot3 by keyboard operation on the teleop_key terminal.
If you move TurtleBot3, you can see that the map is creating on RViz.
- Check the terminal for details of the operation.
- Because of the high image processing load, the robot's camera image transmission interval is set to 1000 [ms].
(If you want to shorten the sending interval, please reduce the Sending Interval of the ZEDMiniPubCameraImageController attached to turtlebot3_with_open_manipulator/RosBridgeScripts)
If you want to finish, stop the Unity side and then the ROS side.
Ubuntu side (It might differ from the latest version)

Windows side (It might differ from the latest version)

Reference Video (It might differ from the latest version)