Robots that are trainable by humans. Each implementation uses the Fido library for its learning model and the cross-platform Fido training app to recieve positive and negative feedback from humans. Experimental results from these two robots are published in the Research repository.
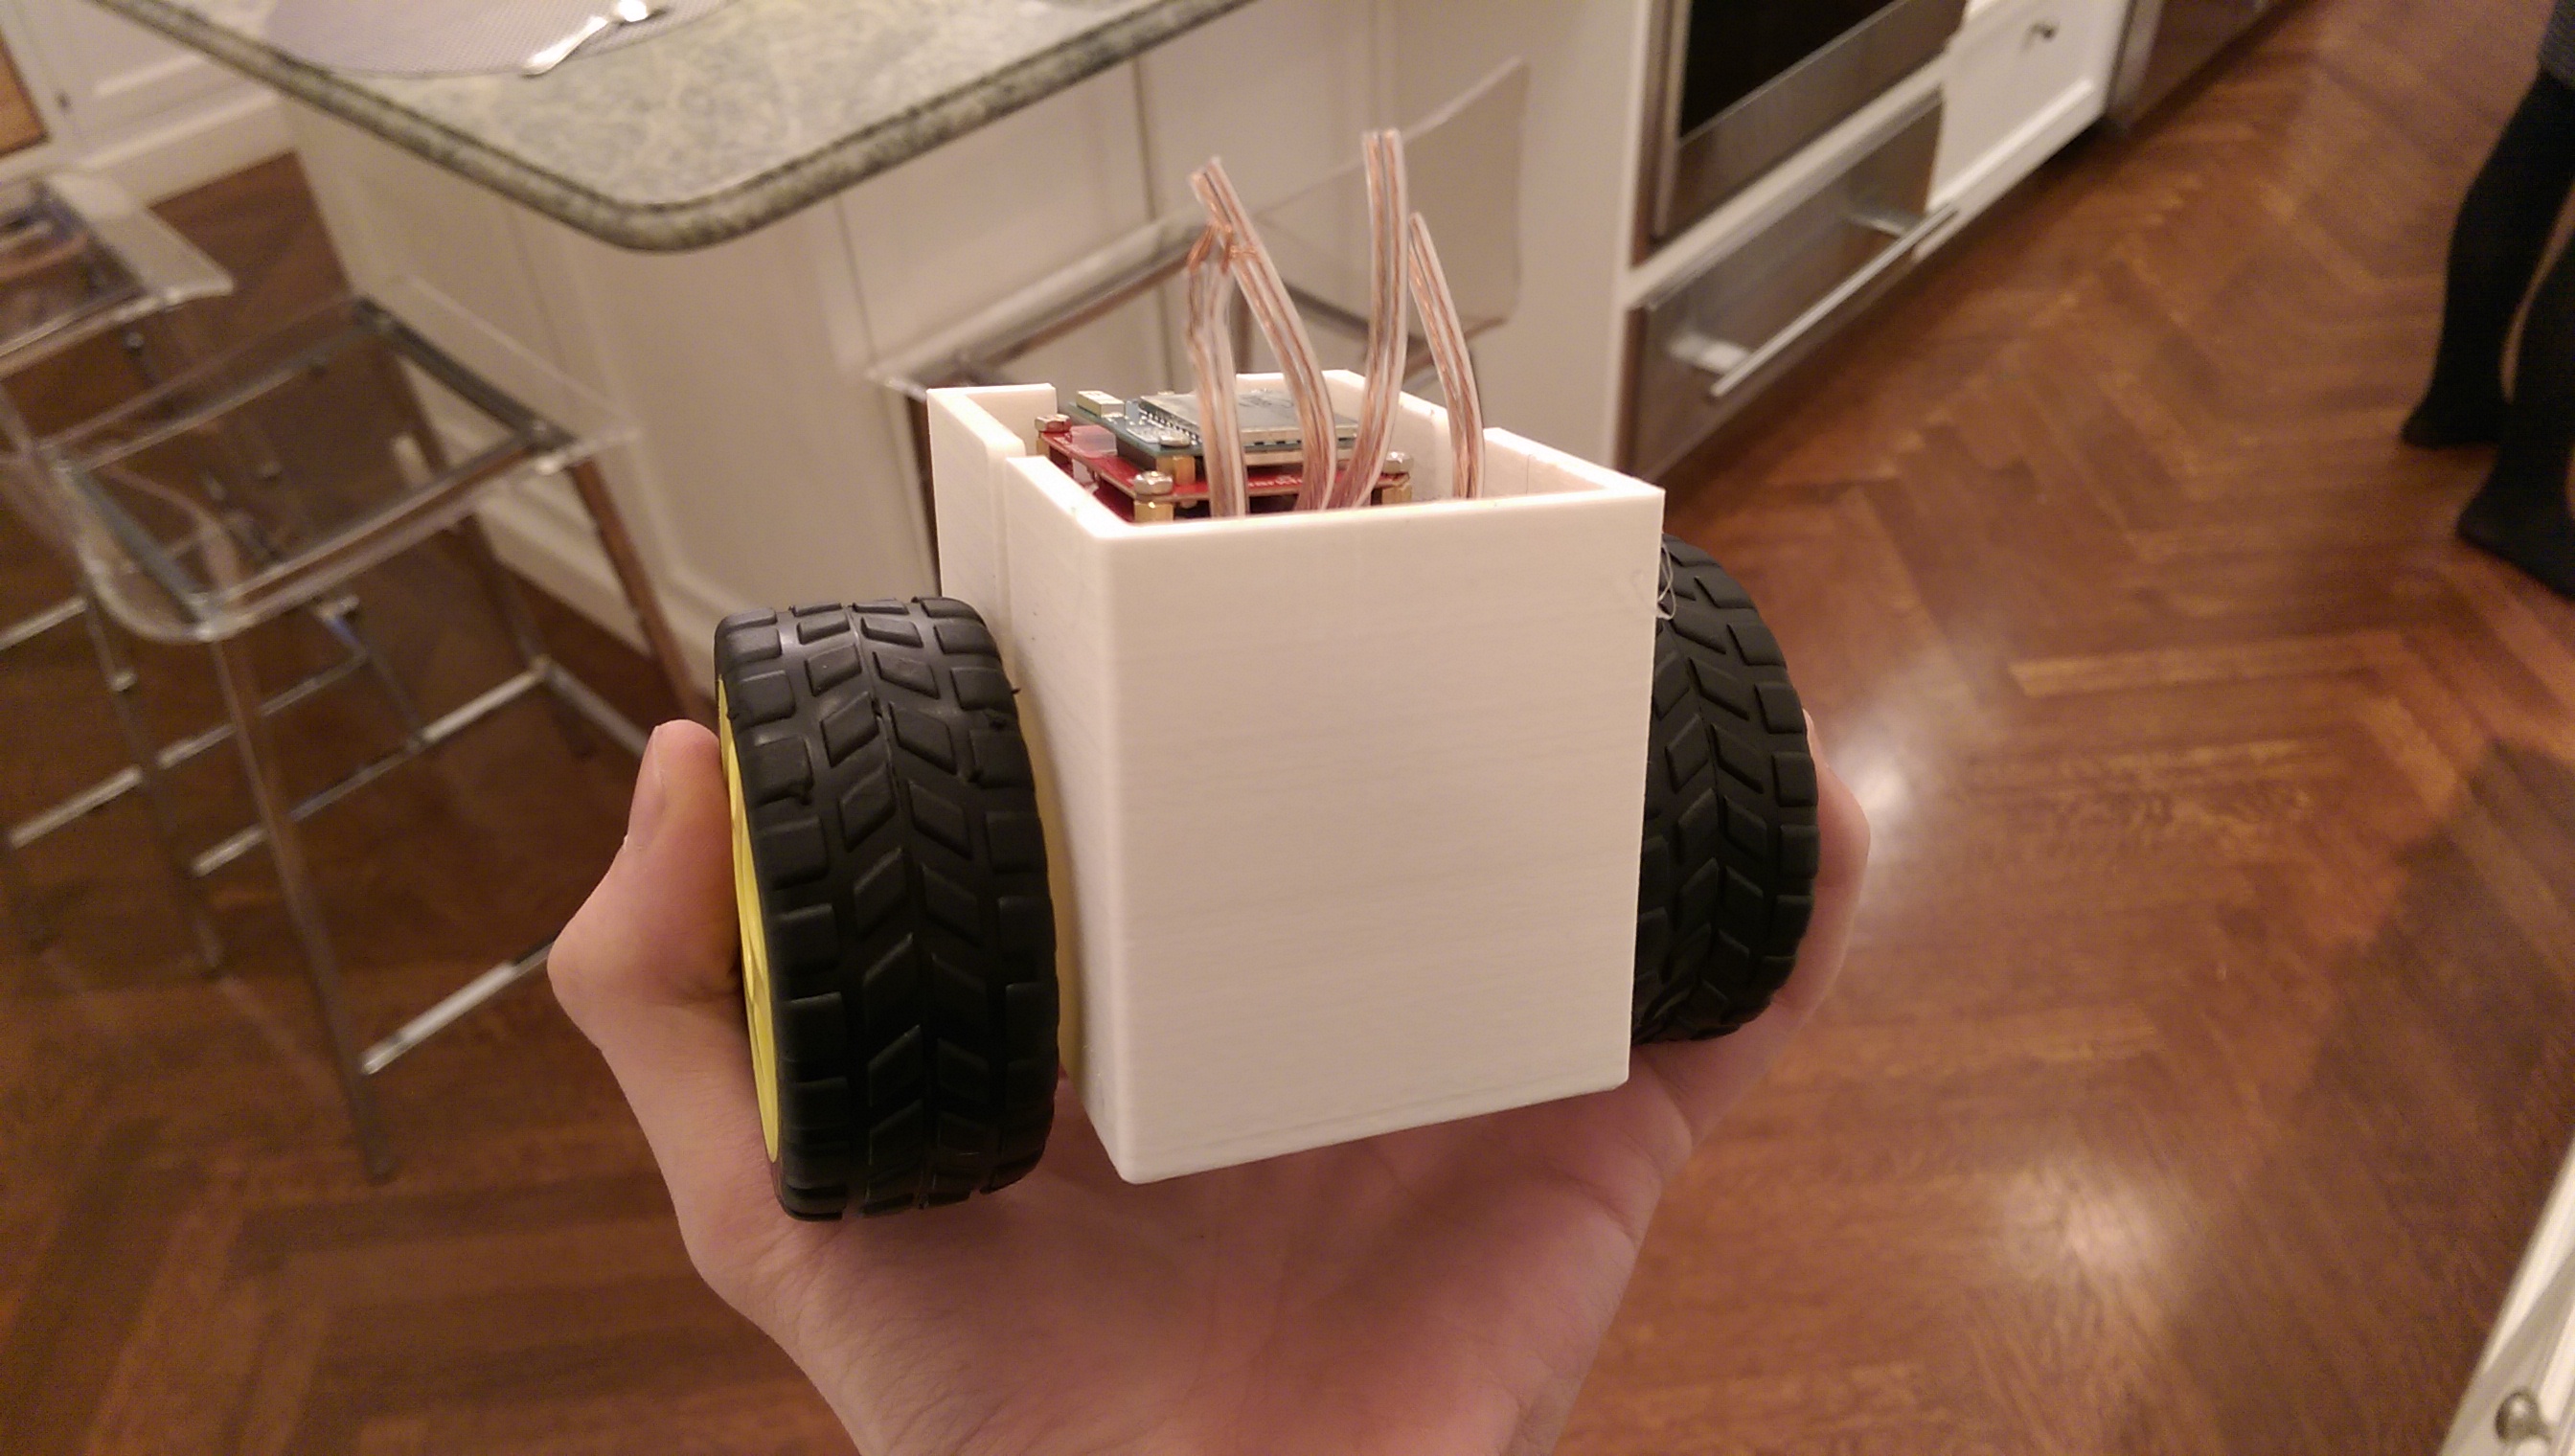
This was the first physical robot that used the Fido library. Previously, the library had been tested on its robotic simulator. "Thing One," as it is called, is powered by an Intel Edison and uses a differential drive system with two wheels. The robot is enclosed in a 3d printed case. Thing One utilizes a wide array of sensors, including an IMU, a light sensor, and a sound pressure sensor.

Processor - $5 Raspberry Pi Zero with a WiFi dongle
Drive System - holonomic drive with three omniwheels
Structure - 4 layers of bolted lexan
Sensors
- IMU
- Z-X sensor
- Line Sensor
Outputs
- LED
- Wheels